Hyunsik Oh.
Doctoral student · KAIST
Robotics & Artificial Intelligence LabDepartment of Mechanical Engineering
About me.
I am a roboticist and doctoral student in Mechanical Engineering at KAIST, advised by Prof. Jemin Hwangbo.
My current research focuses on humanoid robots and bimanual manipulation.
My previous research focused on quadrupedal robots, including reinforcement learning for blind and perceptive locomotion, learning-based state estimation, and dynamic manipulation. I also explored multi-embodiment learning toward foundation models for robot control.
Research interests
Selected work
Selected publications.
IEEE Robotics and Automation Letters
PolyMorph
A shared locomotion policy adapts to robots with different leg counts, joints, and body configurations.
Nature
A marathon on one charge
RAIBO2 combines efficient mechanical design, motor electronics, and locomotion control to complete a marathon on one battery charge.
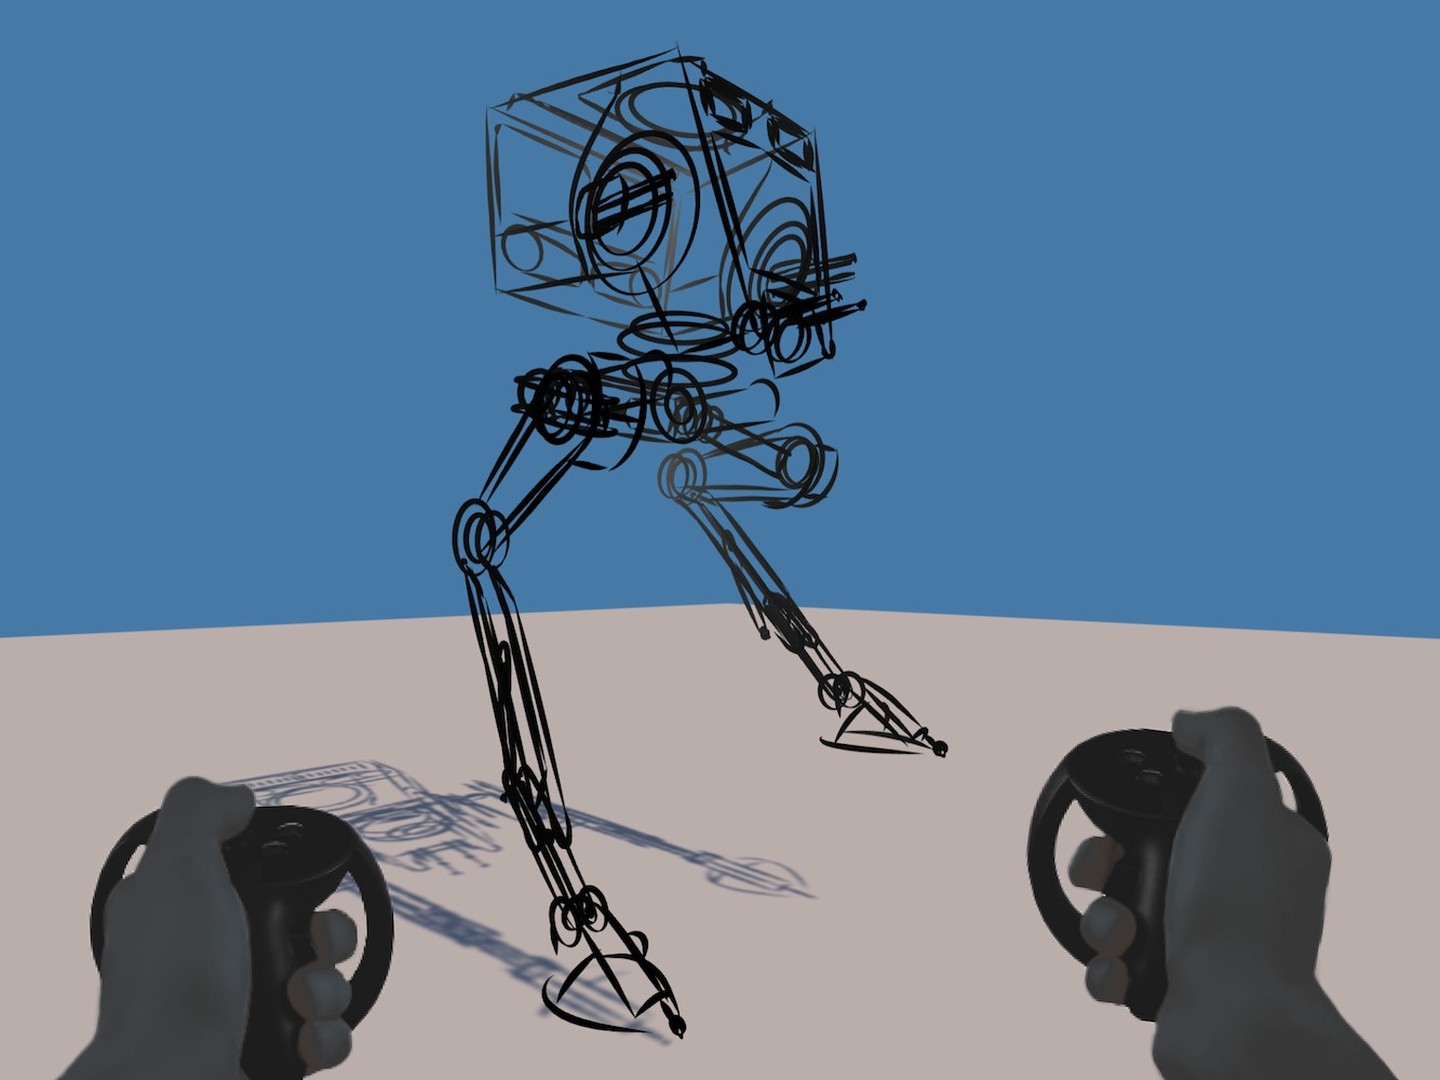
ACM SIGGRAPH 2024 Emerging Technologies
RobotSketch
An interactive system combines 3D sketching, reinforcement learning, and virtual reality to prototype legged robots and their movement.
About & CV
Background.
Doctoral student in the Department of Mechanical Engineering at KAIST.
Robotics & Artificial Intelligence Lab ↗Doctoral student
KAIST · RAI Lab
KAIST
Hanyang University
Let's connect